A paper cup machine rotary encoder and home-position signal should be diagnosed as two related but different references. The encoder reports movement or position according to the delivered control design, while a home or reference sensor establishes a known machine state. A lost pulse, loose coupling, shifted target, damaged cable or incorrect reference sequence can produce missed stations, position alarms or repeatable product defects. The right inspection preserves evidence before anyone changes an offset.
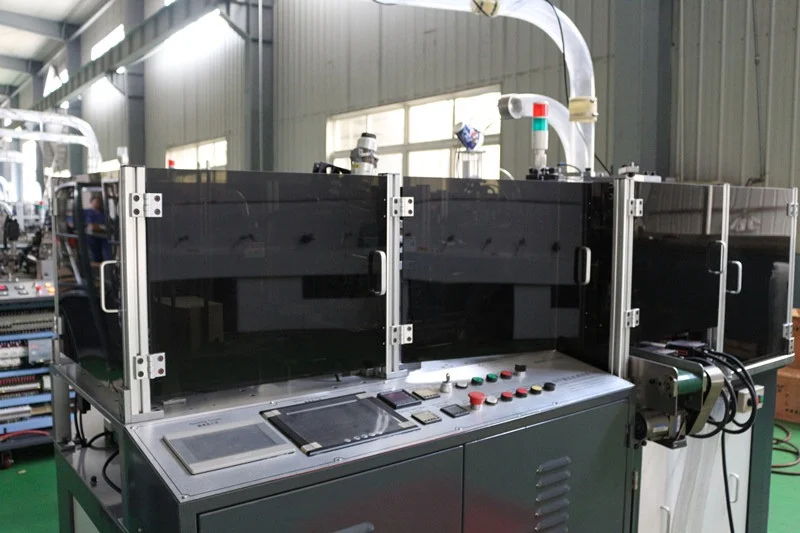
Define what each position device controls
Review the electrical drawing, I/O list, drive documentation and sequence description. Identify the encoder type and mounting, the shaft or motor it follows, any home sensor and target, the controller receiving each signal, and the stations influenced by the reference. Do not assume every machine uses the same absolute, incremental or drive-integrated arrangement.
The sensor and interlock troubleshooting guide covers general detection logic. This guide focuses on the position-reference relationship and the evidence needed before mechanical or software correction.
Preserve the first abnormal sequence
Record the exact alarm text, machine mode, speed stage, product format, last correct cycle and first abnormal station. Note whether the fault appears at power-up, homing, acceleration, steady production, after an emergency stop or after maintenance. Save permitted alarm and trend screens before resetting them.
Mark affected cups by cycle and orientation. A fault that repeats at the same mechanical position is different from random noise or a product-feed problem. Safe external video can help relate the display, station motion and product symptom without entering guarded space.
Use a reference-signal evidence table
| Observed pattern | Evidence to compare | Diagnostic direction |
|---|---|---|
| Machine will not complete homing | Home target, sensor state, axis direction and sequence step | Find the missing reference condition |
| Position drifts during a run | Encoder mounting, coupling, pulse feedback, vibration and drive status | Separate mechanical slip from signal loss |
| Alarm follows recent service | Connector identity, cable route, mounting marks and parameter record | Compare with the pre-service baseline |
| Product defect repeats once per revolution | Shaft reference, station phase, sample orientation and mechanical condition | Map the defect to a physical cycle position |
| Reference changes after power cycle | Homing completion, retained settings, battery or memory status where applicable | Review initialization rather than production offset alone |
Inspect mounting under verified isolation
Apply lockout, verify electrical and mechanical isolation, and prevent stored pneumatic, spring or gravity movement before accessing an encoder, coupling or target. Photograph shaft marks, brackets, connector orientation, cable support and sensor gap references before loosening anything.
Inspect the encoder body, shaft connection, flexible coupling where fitted, key or locking device, bracket, fasteners and guarding. Look for fretting, cracked elements, shaft movement, impact, contamination or displaced witness marks. Do not rotate a timed shaft or tighten a coupling without the approved machine-position procedure.
Check the home target and detection geometry
Inspect the home sensor, target or flag, bracket rigidity, sensing face, contamination and cable strain. Confirm that the target approaches in the designed direction and does not strike the sensor. A sensor indication on the HMI does not prove repeatable switching at the correct physical point.
Measure gap, alignment or repeat position only with the supplier’s method and suitable tools. Do not bend a target repeatedly to chase an alarm. If the reference has moved, determine whether a loose support, collision, bearing movement or incorrect reassembly caused it.
Trace the signal path without forcing outputs
Qualified personnel should compare physical position with permitted input, drive and controller indications. Inspect connectors, shields, glands, flexible cable sections and separation from motor, heater or other power wiring. Evidence of intermittent feedback may appear only during movement, vibration or temperature change.
Do not bypass the home input, force a controller bit or alter encoder scaling as a shortcut. Those actions can hide the failure and create collision risk. Preserve parameter backups and use approved diagnostic access.
Separate reference loss from axis mechanics
An axis can lag because of binding, overload, brake behavior, coupling slip, bearing wear or a driven mechanism even when feedback signals are present. Compare commanded state, physical motion and station result in order. Check whether the drive reaches home but the product handoff still fails.
Use the servo synchronization guide when a controlled axis reports following or coordination faults. Final drive and encoder relationships remain model- and configuration-specific.
Prove repeatability after correction
After authorized work, account for tools, restore guards and complete the documented reference sequence. Record the first home position, repeat the sequence as permitted, and confirm that physical marks and controller indications remain consistent.
Run labeled cups through controlled speed stages. Inspect the stations influenced by the reference and retain first-off samples. Release production only after alarms, position evidence, machine motion and cup quality remain stable across the agreed observation period.
Frequently asked questions
Can an encoder offset be changed when a station is late?
Not before mechanical position, homing, coupling, feedback integrity and the approved parameter baseline are verified. An offset can hide the first cause.
Does an active home input prove the machine is referenced correctly?
No. The sensor may switch at the wrong physical point, remain active too long or be read in an incorrect sequence. Compare the target and motion.
Why can an encoder fault appear only at higher speed?
Vibration, cable movement, coupling slip, electrical interference, axis load or response limitations may become visible during acceleration or faster cycling.
What evidence should be sent for remote review?
Provide the machine model, alarm text, reference sequence, safe cycle video, mounting photos under isolation, signal indications, parameter backup status and affected samples.
Send the machine model, encoder and home-device identity, alarm history, isolated mounting photos, permitted signal evidence and cycle-marked cup samples through our inquiry page. HANNAI can review the reference chain for the supplied configuration.